Hi, I'm

Zhiang "Ryan" Chen

Computer Vision Researcher

I build systems that interact with the visual world in 3D — from robust point cloud assembly to scene understanding for robotics and beyond.

Scroll

About

I'm a CS Masters student at ETH Zürich focusing on 3D vision research, working at the intersection of deep learning and geometric understanding. My interests span areas including 3D shape assembly, scene registration, and vision for robotics.

Research Interests

3D Assembly Scene Understanding Multi-View Geometry Robotics

Publications

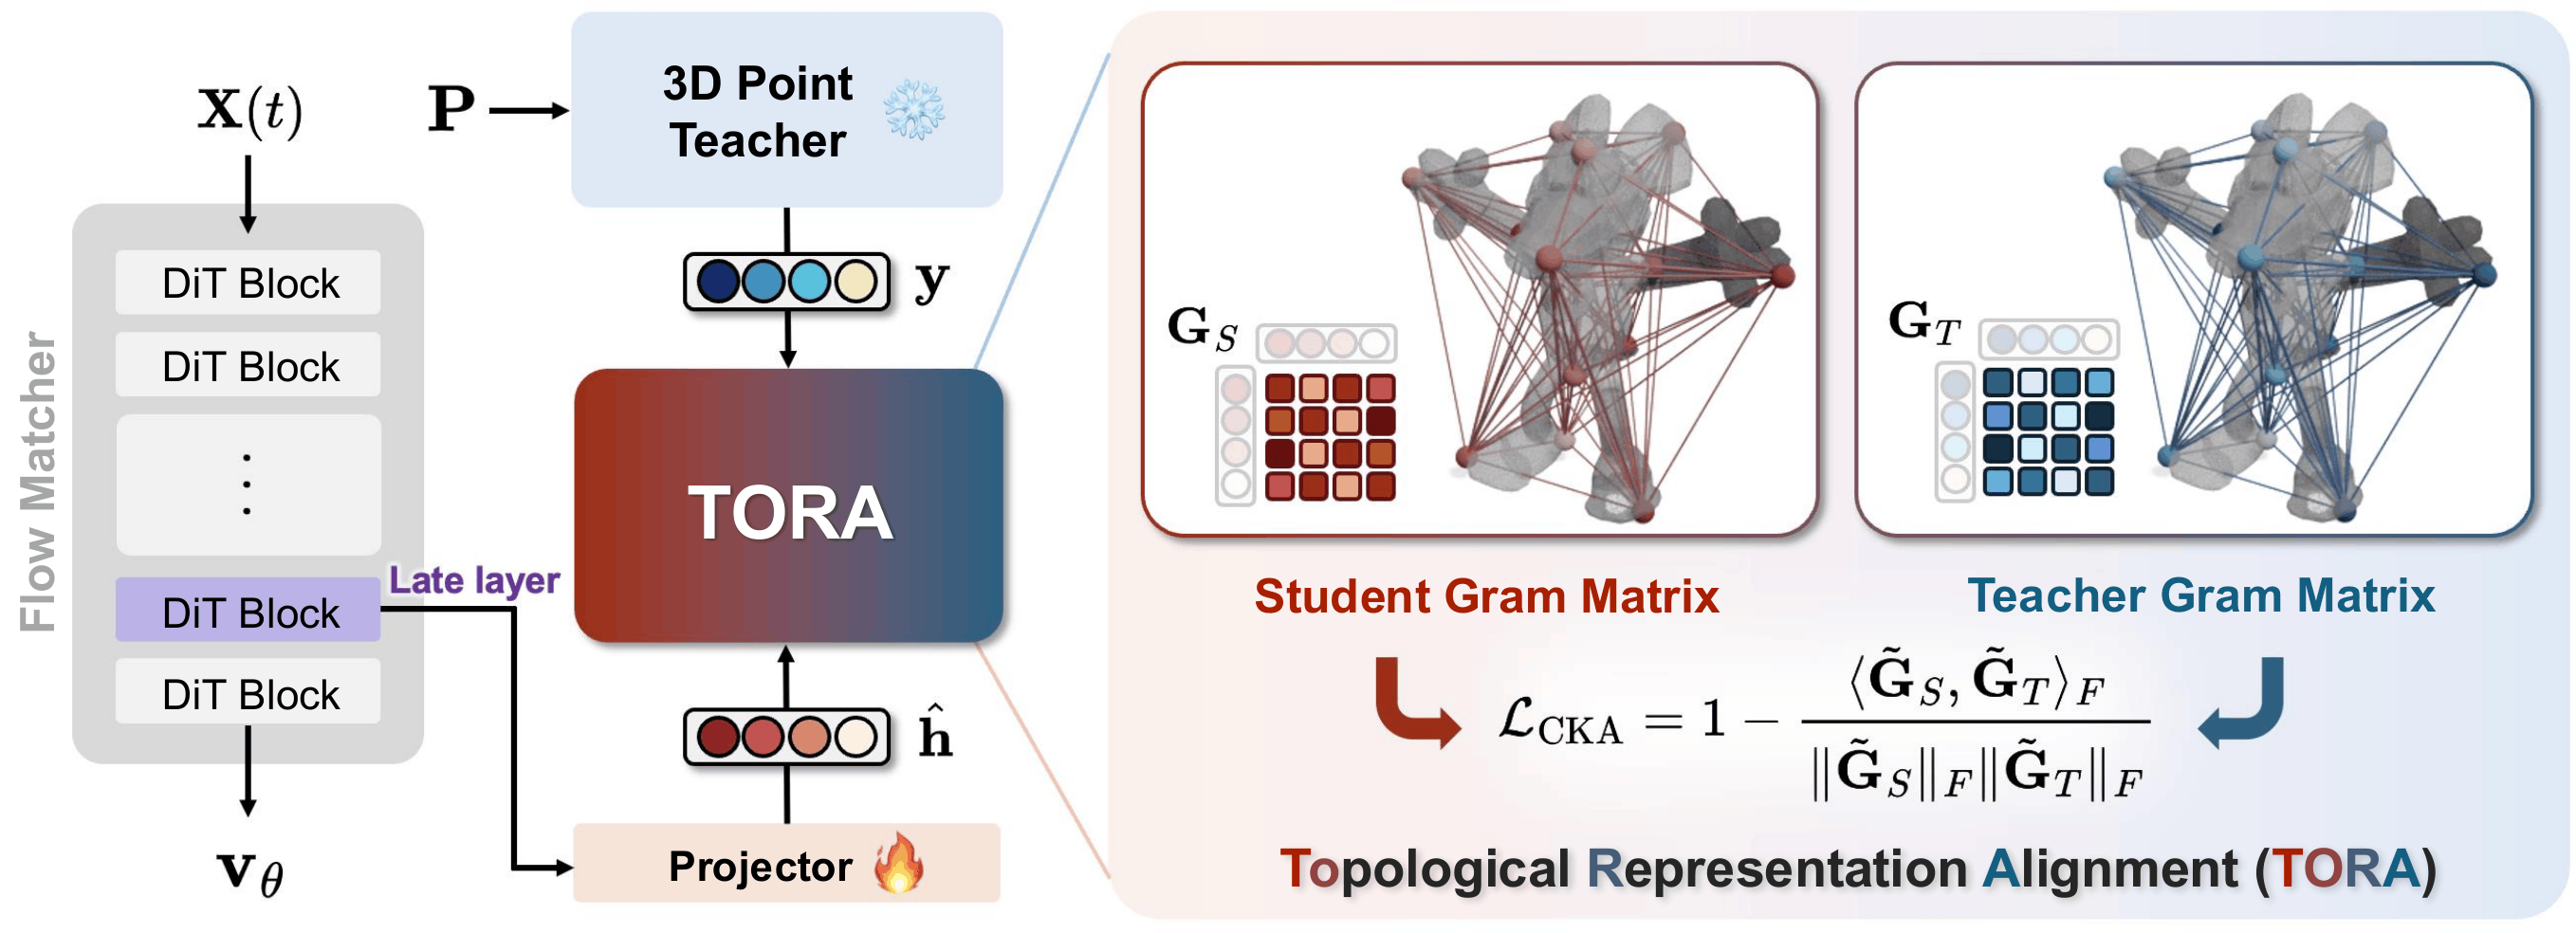
TORA paper figure

TORA: Topological Representation Alignment for 3D Shape Assembly

Nahyuk Lee, Zhiang Chen, Marc Pollefeys, Sunghwan Hong

ECCV 2026

By distilling relational geometric structure from a frozen pretrained 3D encoder into a flow-matching assembly backbone via token-wise cosine and CKA alignment losses, TORA achieves faster convergence (up to 6.9×), improved in-distribution accuracy, and stronger zero-shot transfer across five benchmarks with zero additional inference cost.
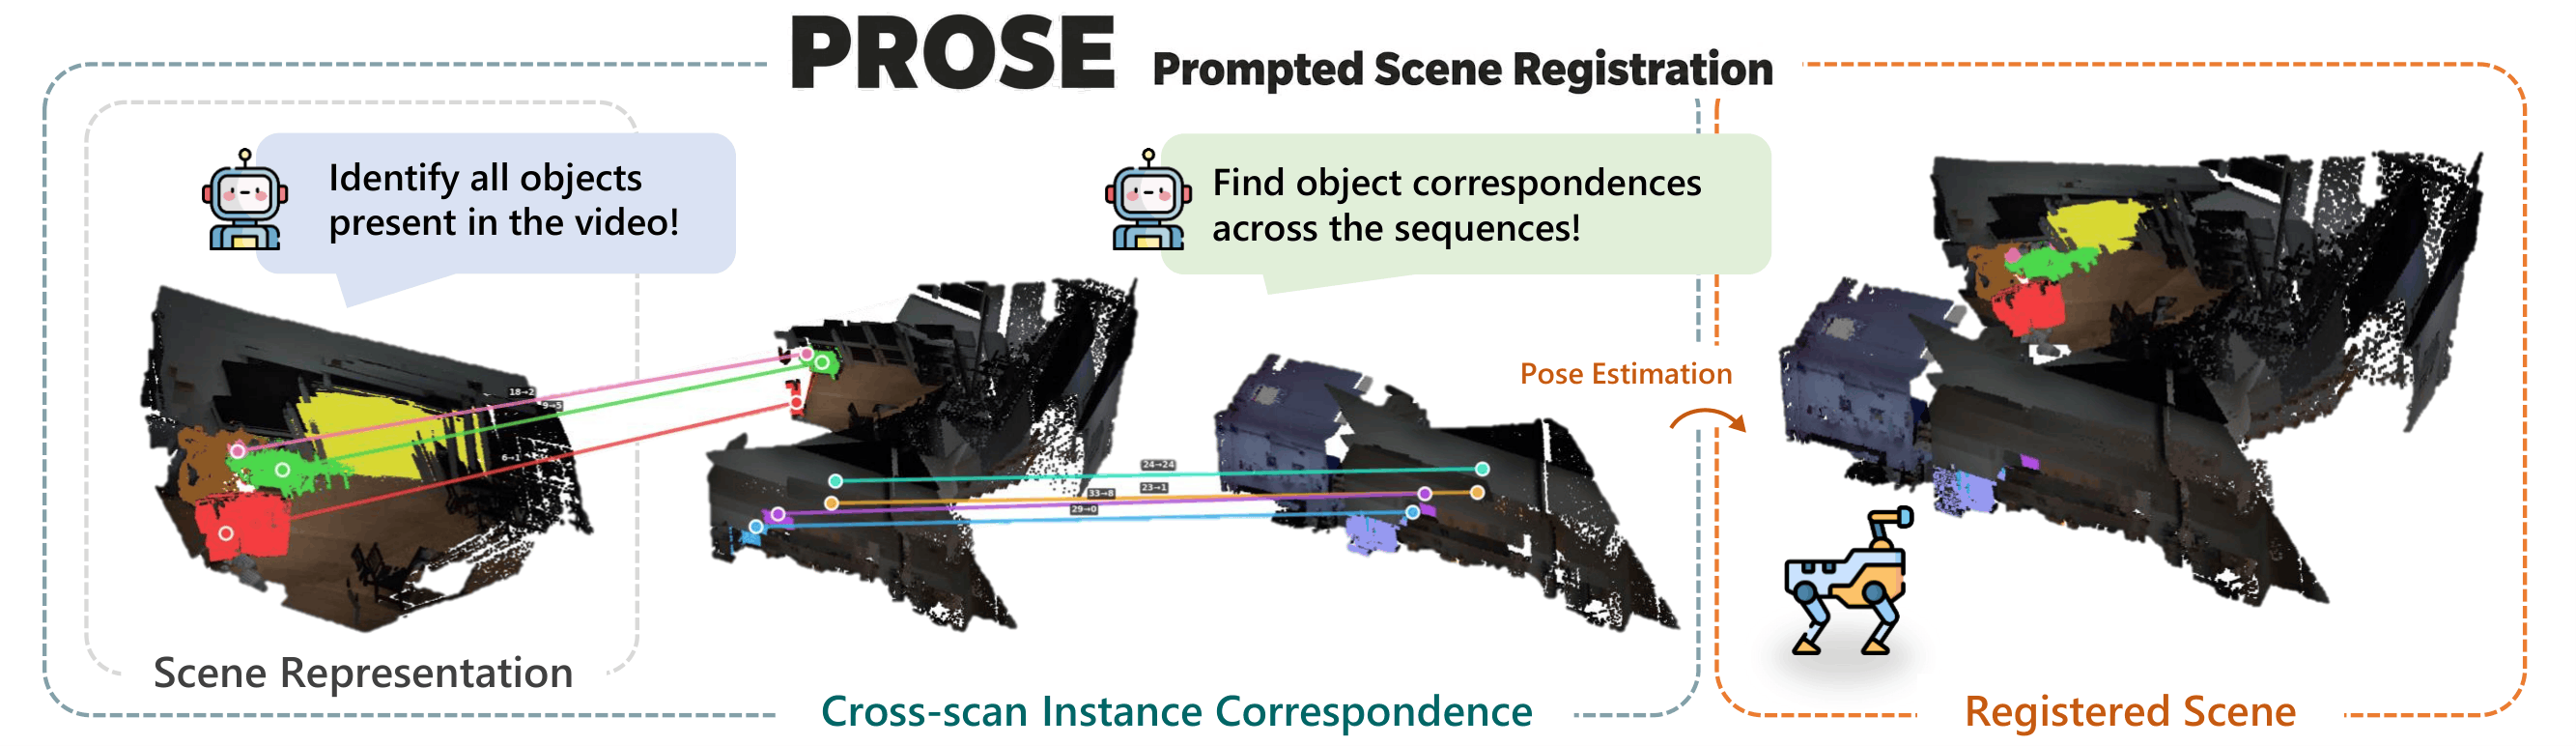
PROSE paper figure

PROSE: Training-Free Egocentric Scene Registration with Vision-Language Models

Zhiang Chen, Nahyuk Lee, Sun Boyang, Taein Kwon, Marc Pollefeys, Zuria Bauer, Sunghwan Hong

CoRL 2026

Without any training, depth sensors, or learned parameters, PROSE achieves state-of-the-art cross-session registration on egocentric benchmarks. It lifts RGB-only sequences into object-level 3D scene graphs using off-the-shelf foundation models, then leverages a vision-language model to match object instances across sessions using height binning and geometric consensus verification.

Projects

To be updated — check back soon!

Contact

Interested in collaborating or have questions about my work? Feel free to reach out.